SUN YAT-SEN UNIVERSITY UNDERGRADUATE

Yue Chen陈越

Document intelligence.
Multimodal learning.
Retrieval-augmented generation.

Studying Microelectronics Science and Engineering, with research and projects in document parsing, evidence-enhanced analysis, and physical state estimation.

Seeking an algorithm research internship

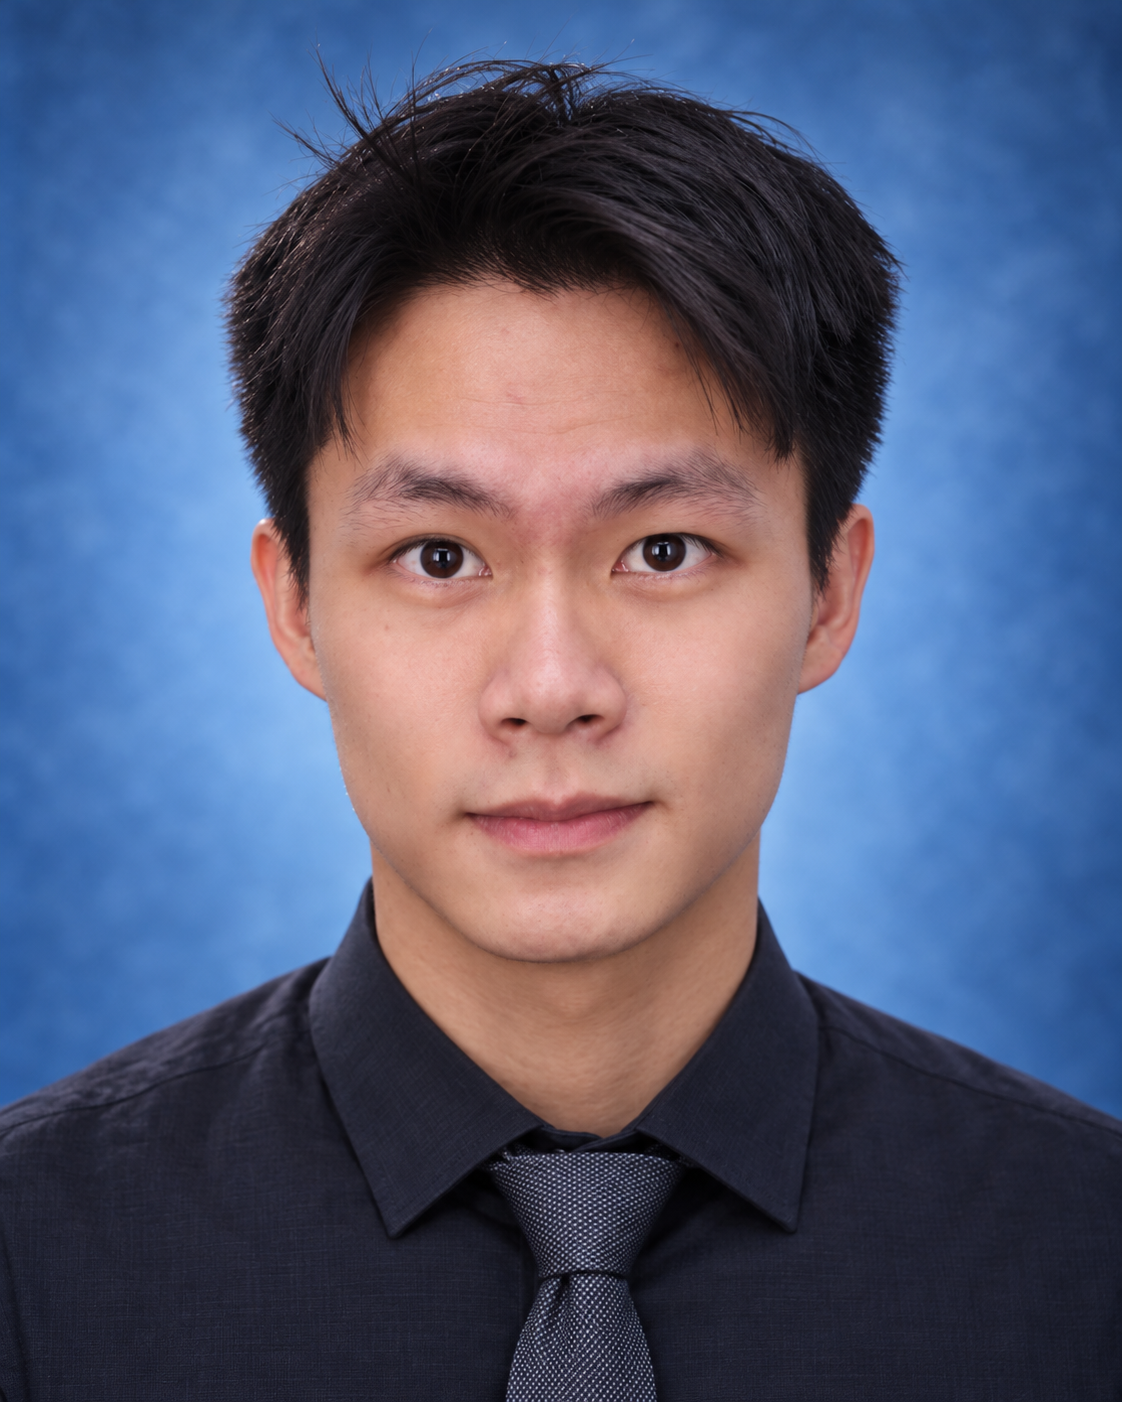
Portrait of Yue Chen
YUE CHENRESEARCH & CV / 2026

01 / RESEARCH

Research & algorithm projects

Document structure, evidence, and physical understanding.

ProSA

2026

Structural Robustness Auditing for Document Parsing

EMNLP 2026 Main · AcceptedFirst author
  • Led the development of ProSA, an auditing framework requiring no access to parser internals. To address Footprint Bias in measuring parsing damage by perturbation area, designed the block-level structural loss rate B-SLR to jointly assess block locations and text preservation.
  • Led the research direction, experimental design and core validation; evaluated MinerU and PP-StructureV3 and analyzed how structural errors propagate to downstream question answering and retrieval.
  • Across 1,000 document pages and 29 fixed perturbation configurations, B-SLR achieved fitted R² values of 0.727 / 0.916 against changes in OCR character error rate, exceeding 0.384 / 0.110 for the area-based metric.
Document intelligenceRobustness auditingModel evaluation

SAE

2026

Sprint Video Analysis and Evidence-Augmented Reports

Under review at JSAMSCo-first author · Second-listed author
  • Contributed to the SEE–ASSESS–EXPLAIN framework, combining pose estimation from single-view video, phase-specific rule assessment, literature retrieval and LLM explanations to generate technique analysis reports with cited evidence.
  • Contributed to expert agreement, retrieval and evidence comparison evaluations. Across 1,008 fixed phase-specific rule assessments from 112 sprint trials, rule judgments agreed with the majority judgment of three experts in 93.2% of cases.
Video analysisEvidence retrievalLLM explanations

Physical Belief

2026–Present

Multimodal Physical State Estimation for Robots

Multimodal fusion · Temporal modeling
  • Fuse RGB-derived poses, robot states and interaction history using an MLP + GRU to estimate object mass, friction and center of mass, building a physical state representation continuously updated through interaction.
  • Conduct training under multiple conditions, temporal ablations and generalization evaluations. In completed in-domain tests, full history reduced friction estimation MAE by approximately 65% relative to a short-history baseline.
RoboticsMultimodal fusionTemporal modeling

OTHER PROJECT

Personalized Education RAG System

Undergraduate Innovation and Entrepreneurship Training Program · Project lead
  • Lead the technical roadmap and project execution; designed a personalized education system combining course knowledge bases, user information, retrieval and generation.
RAGPersonalized education

02 / BACKGROUND

Education, honors & skills

Education

Sun Yat-sen University

Microelectronics Science and Engineering

Undergraduate

2024–2028

Honors & awards

  • National ScholarshipFirst-Class Outstanding Student Scholarship, Sun Yat-sen University
  • Third-Class Outstanding Student ScholarshipSun Yat-sen University
  • First PrizeGuangdong Provincial Mathematics Competition for College Students
  • Second PrizeChina Undergraduate Mathematical Contest in Modeling · Guangdong Division

Skills

Programming & tools

Python · PyTorch · MuJoCo

Research & practice

Document Intelligence / DLA · RAG / Agents · Temporal Deep Learning · Multimodal Fusion · Model Evaluation

English

College English Test Band 6 (CET-6): 579

03 / CONTACT

Let's connect.

For algorithm research internship opportunities.